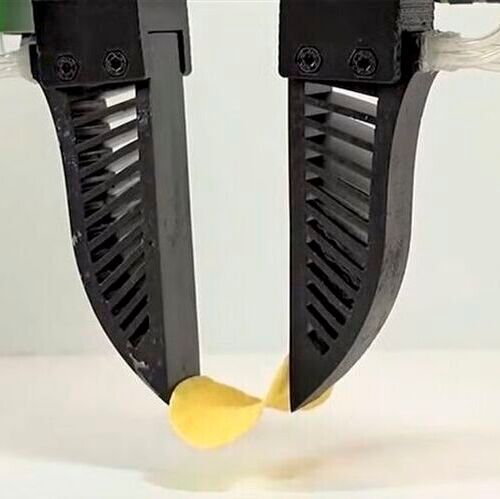
A new robotic hand makes use of the Forte technology to grasp objectives that are sensitive to touch such as a potato chip or raspberries without crushing it. The innovation has the potential to improve robot performances in food processing, health care and manufacturing.
The fingers at the heart of this technology were inspired by the fin-ray effect — a design principle derived from the natural structure of fish fins.
(Source: University of Texas at Austin)
Texas/USA – A new type of robotic hand developed at The University of Texas at Austin demonstrates such sensitive touch that it can grasp objects as fragile as a potato chip or a raspberry without crushing them. The technology, called Fragile Object Grasping with Tactile Sensing (Forte), combines advanced tactile sensing with soft robotics. The breakthrough could improve robot performance when a light touch is needed, such as in health care and manufacturing.
“Right now, robotics is starting to be able to do large motions around the house, but struggles with really fine and delicate movements,” said Siqi Shang, lead author of a new paper published in IEEE Robotics and Automation Letters and a doctoral student in the Cockrell School of Engineering’s Chandra Family Department of Electrical and Computer Engineering. “Robots can fold a shirt but may struggle to carefully pick up your glasses or unpack fruit from your groceries. “We believe sensing signals will give robots a sense of touch to handle these objects carefully.”
The fingers at the heart of this technology were inspired by the fin-ray effect — a design principle derived from the natural structure of fish fins. These fingers are made using advanced 3D-printing techniques and feature internal, empty air channels that act as tactile sensors. The researchers recently applied the sensing technology to a year-long collaboration with the College of Fine Arts’ Department of Theatre and Dance.
When the fingers prepare to grasp an object, the air channels inside them also shift, causing changes in air pressure. These pressure changes are detected by small, off-the-shelf sensors that provide real-time force feedback to the robot and let it know whether the object is slipping.
The researchers tested the grippers on 31 objects, including fragile items such as raspberries and potato chips, slippery items such as jam jars and billiard balls, and everyday items such as soup cans and apples. The system achieved a 91.9 % success rate in single-trial grasping experiments, outperforming traditional grippers that rely solely on visual feedback.
The system recognized 93 % of slips with 100 % precision, meaning it never falsely identified a slip event. This high level of precision ensures that the robot adjusts its grip only when necessary, avoiding excessive force that could damage an object.
“Humans pick up objects with just the right amount of force; too much and you’ll crush it, but too little and it’ll slip out of your hand,” said Lillian Chin, assistant professor of electrical and computer engineering at UT. “Most current force sensors aren’t fast or accurate enough to provide that Goldilocks level of detail. In particular, our sensors operate closer to the timescales of human hand sensors.”
In addition to speed and accuracy, these fingers have a longer lifespan than other devices under development. Because the sensors are 3D printed, they can be easily customized to a variety of shapes.
The slip-sensing ability is what really distinguishes them. Very few robotic gripping technologies have slip detection at all, and those that do can’t match Forte’s reaction time and speed.
Forte is a significant milestone in the quest to create robot hands with dexterity similar to that of humans, and it could affect many industries:
In food processing, where handling fragile items such as fruits, vegetables and baked goods is a daily challenge, more sensitive machinery could reduce waste and improve efficiency.
In health care, robots could handle medical instruments or fragile biological samples with precision.
In manufacturing, the technology could be used to handle delicate components, such as electronics or glassware.
The researchers have publicly released the hardware designs and algorithms to encourage other scientists and engineers to build upon their work. They’re still fine-tuning the technology, and the next steps include making the sensors less sensitive to temperature changes and improving the ability to catch objects that are slipping.
The project team also includes Yuke Zhu, associate professor in the College of Natural Sciences’ Department of Computer Science, and doctoral student Mingyo Seo. The research was supported by the Texas Robotics Industrial Affiliate Program, the National Science Foundation, the Office of Naval Research, the Darpa Tiamat program, and South Korea’s Institute of Information & Communications Technology Planning & Evaluation.
Date: 08.12.2025
Naturally, we always handle your personal data responsibly. Any personal data we receive from you is processed in accordance with applicable data protection legislation. For detailed information please see our privacy policy.
Consent to the use of data for promotional purposes
I hereby consent to Vogel Communications Group GmbH & Co. KG, Max-Planck-Str. 7-9, 97082 Würzburg including any affiliated companies according to §§ 15 et seq. AktG (hereafter: Vogel Communications Group) using my e-mail address to send editorial newsletters. A list of all affiliated companies can be found here
Newsletter content may include all products and services of any companies mentioned above, including for example specialist journals and books, events and fairs as well as event-related products and services, print and digital media offers and services such as additional (editorial) newsletters, raffles, lead campaigns, market research both online and offline, specialist webportals and e-learning offers. In case my personal telephone number has also been collected, it may be used for offers of aforementioned products, for services of the companies mentioned above, and market research purposes.
Additionally, my consent also includes the processing of my email address and telephone number for data matching for marketing purposes with select advertising partners such as LinkedIn, Google, and Meta. For this, Vogel Communications Group may transmit said data in hashed form to the advertising partners who then use said data to determine whether I am also a member of the mentioned advertising partner portals. Vogel Communications Group uses this feature for the purposes of re-targeting (up-selling, cross-selling, and customer loyalty), generating so-called look-alike audiences for acquisition of new customers, and as basis for exclusion for on-going advertising campaigns. Further information can be found in section “data matching for marketing purposes”.
In case I access protected data on Internet portals of Vogel Communications Group including any affiliated companies according to §§ 15 et seq. AktG, I need to provide further data in order to register for the access to such content. In return for this free access to editorial content, my data may be used in accordance with this consent for the purposes stated here. This does not apply to data matching for marketing purposes.
Right of revocation
I understand that I can revoke my consent at will. My revocation does not change the lawfulness of data processing that was conducted based on my consent leading up to my revocation. One option to declare my revocation is to use the contact form found at https://contact.vogel.de. In case I no longer wish to receive certain newsletters, I have subscribed to, I can also click on the unsubscribe link included at the end of a newsletter. Further information regarding my right of revocation and the implementation of it as well as the consequences of my revocation can be found in the data protection declaration, section editorial newsletter.